Graduation Project 2024 – Canadian University Dubai
Automated SCARA Robot Arm
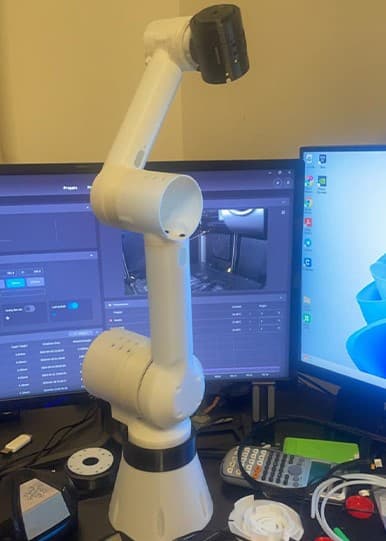
Designed and built a 4-axis SCARA robot arm for automated pick-and-place and repeatable precision motion.
- Year
- 2024
- Location
- Dubai, UAE
- Tools and methods
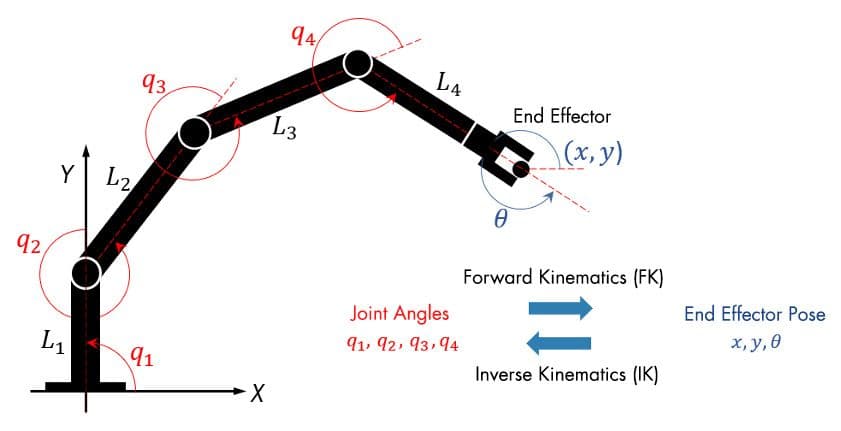
- Mechatronics, Motion Control, Inverse Kinematics, Automation
Mechanical Design
The SCARA arm was modeled in CAD with focus on stiffness, reach, and ease of assembly.
Each joint was sized based on torque requirements to ensure smooth and precise motion under load.
Control & Software
Implemented kinematics and motion profiles to move the end-effector between programmed waypoints.
The system supports automated sequences for pick-and-place tasks and can be extended with vision in future iterations.
Media